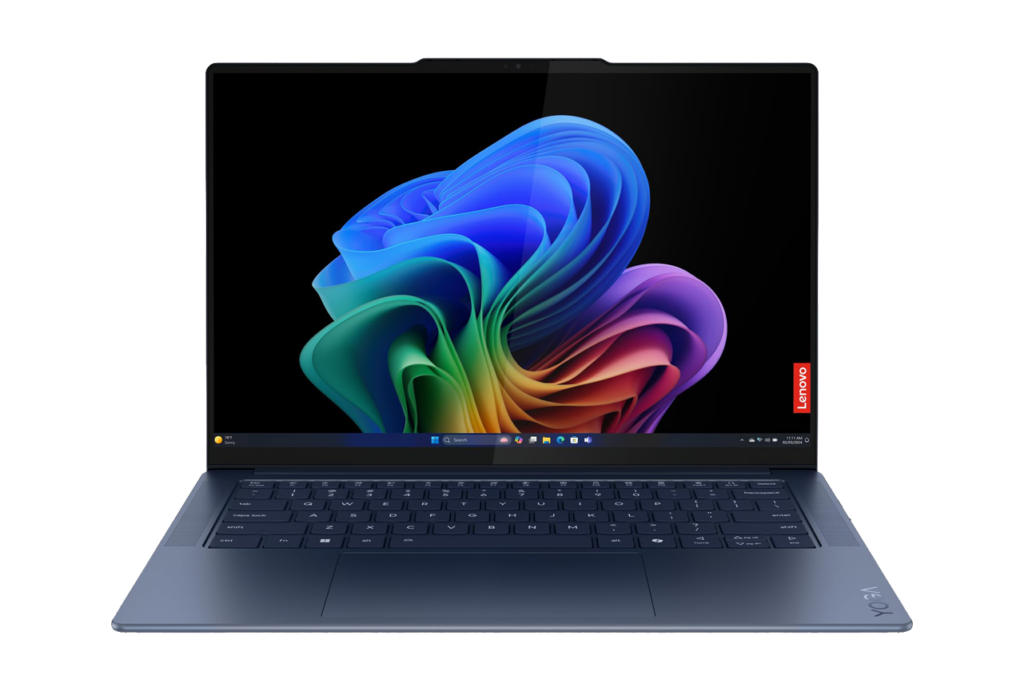
We put the Lenovo Yoga Slim 7x Gen9 inch through our rigorous DXOMARK Laptop test suite to measure its performance in sound, camera and display. In this review, we will break down how it fared in a variety of tests and several common use cases.
Overview
Scoring
Use-case and feature subscores included in the calculations of the global score
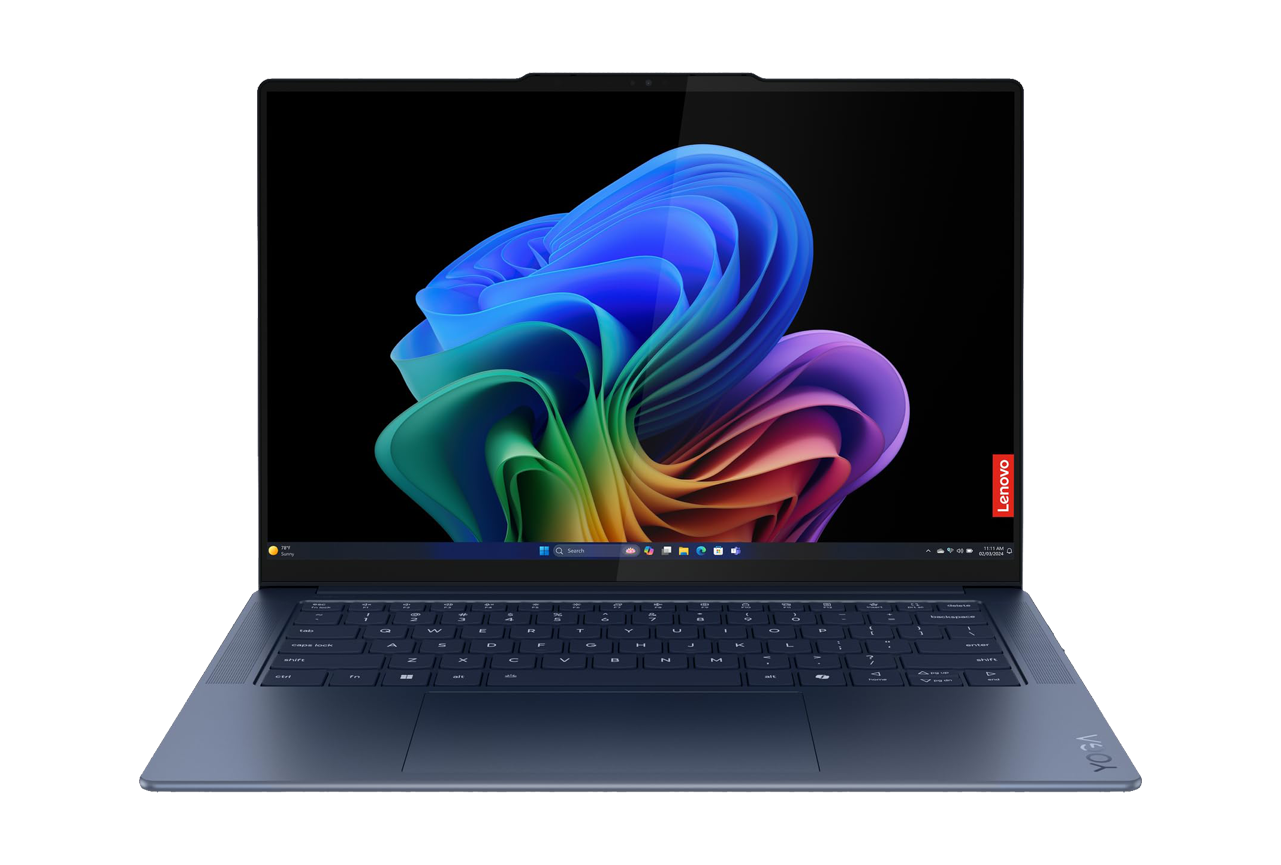 Lenovo Yoga Slim 7x Gen 9

88
camera
69
Microsoft Surface Pro 13-inch
Best: Microsoft Surface Pro 13-inch (93)
42
Lenovo ThinkPad X9 Aura
Best: Lenovo ThinkPad X9 Aura (56)
61
Microsoft Surface Laptop 13.8-inch
Best: Microsoft Surface Laptop 13.8-inch (84)
47
Apple MacBook Pro 14" (M5; 2025)
Best: Apple MacBook Pro 14" (M5; 2025) (85)
73
Microsoft Surface Laptop 13.8-inch
Best: Microsoft Surface Laptop 13.8-inch (146)
100
Microsoft Surface Laptop 13.8-inch
Best: Microsoft Surface Laptop 13.8-inch (146)
Pros
- Very high detail levels across all tested lighting conditions
- Good face exposure in challenging lighting conditions
- Acceptable color rendering in bright conditions with static subjects
Cons
- Highly visible noise in indoor and low-light conditions
- Noticeable exposure and white balance instabilities during motion
- Visible clipping in low-light HDR conditions
- Inaccurate skin tone rendering
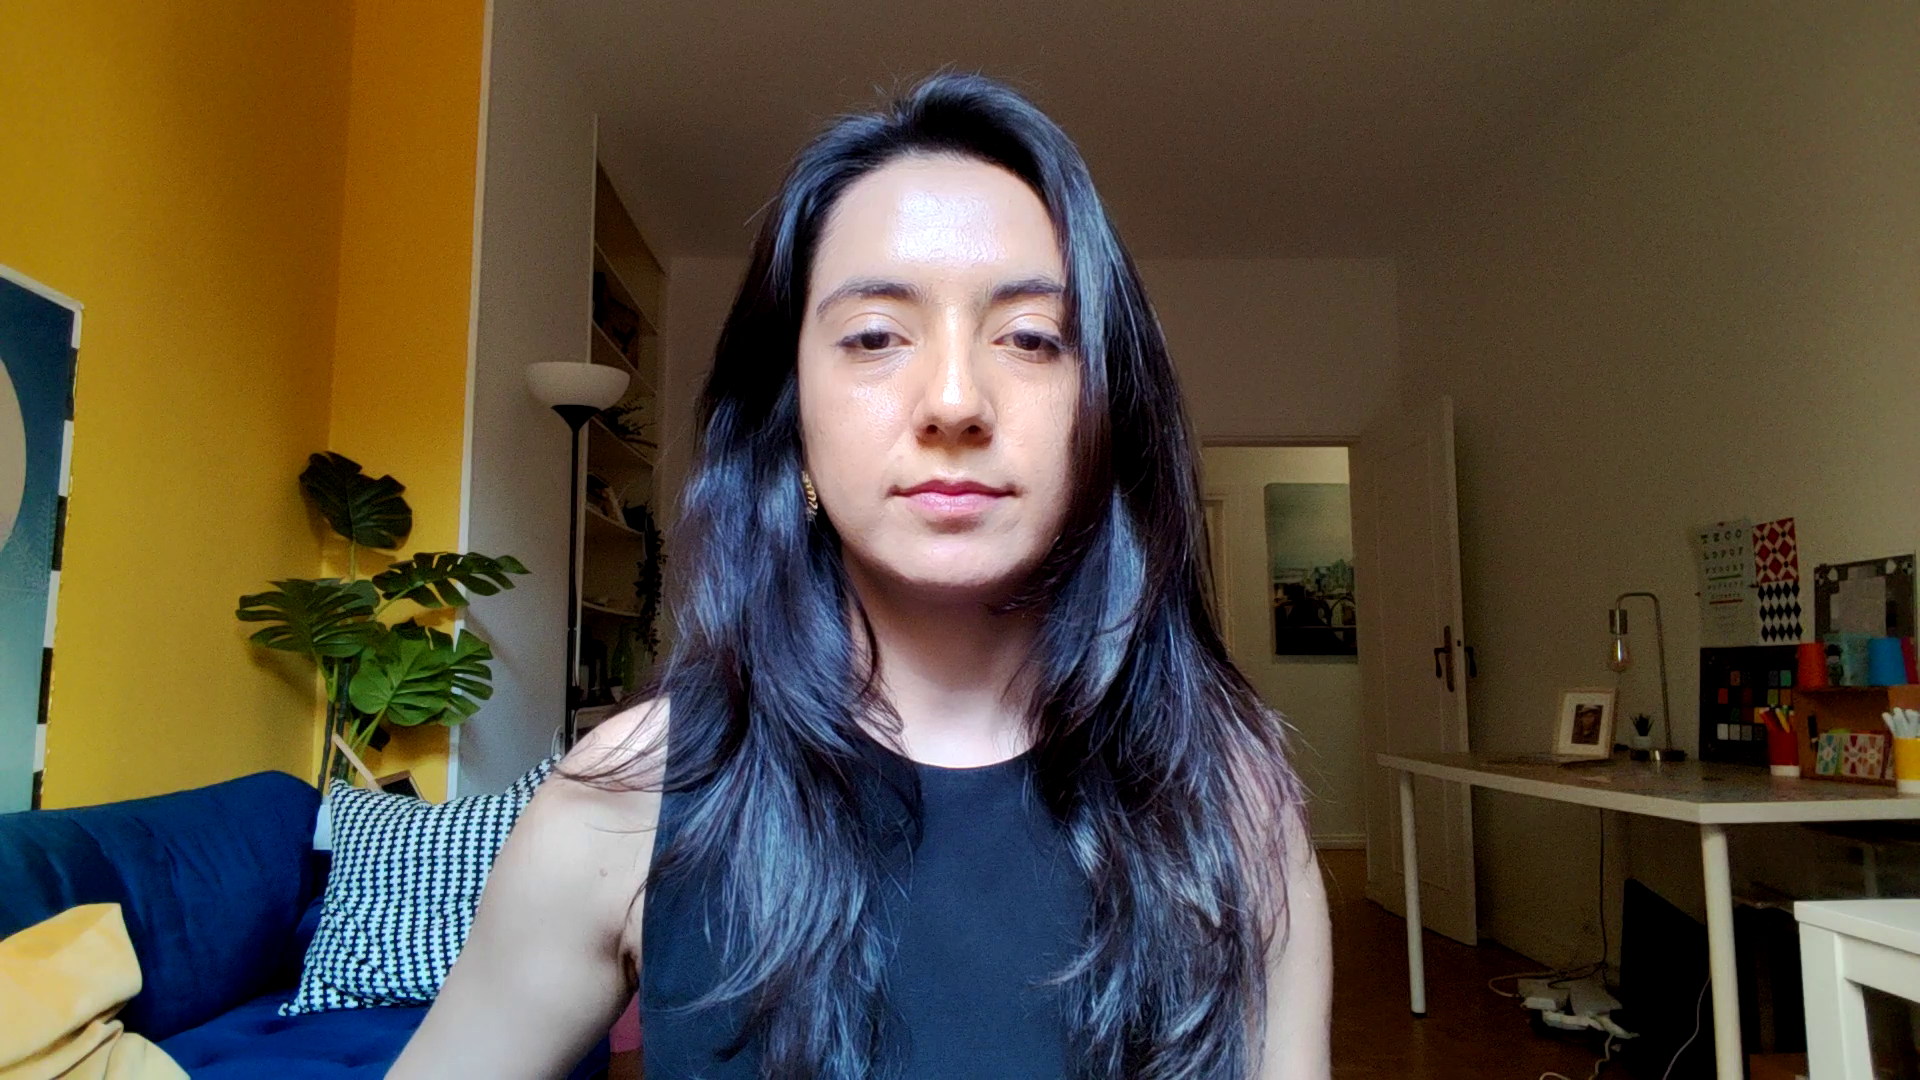
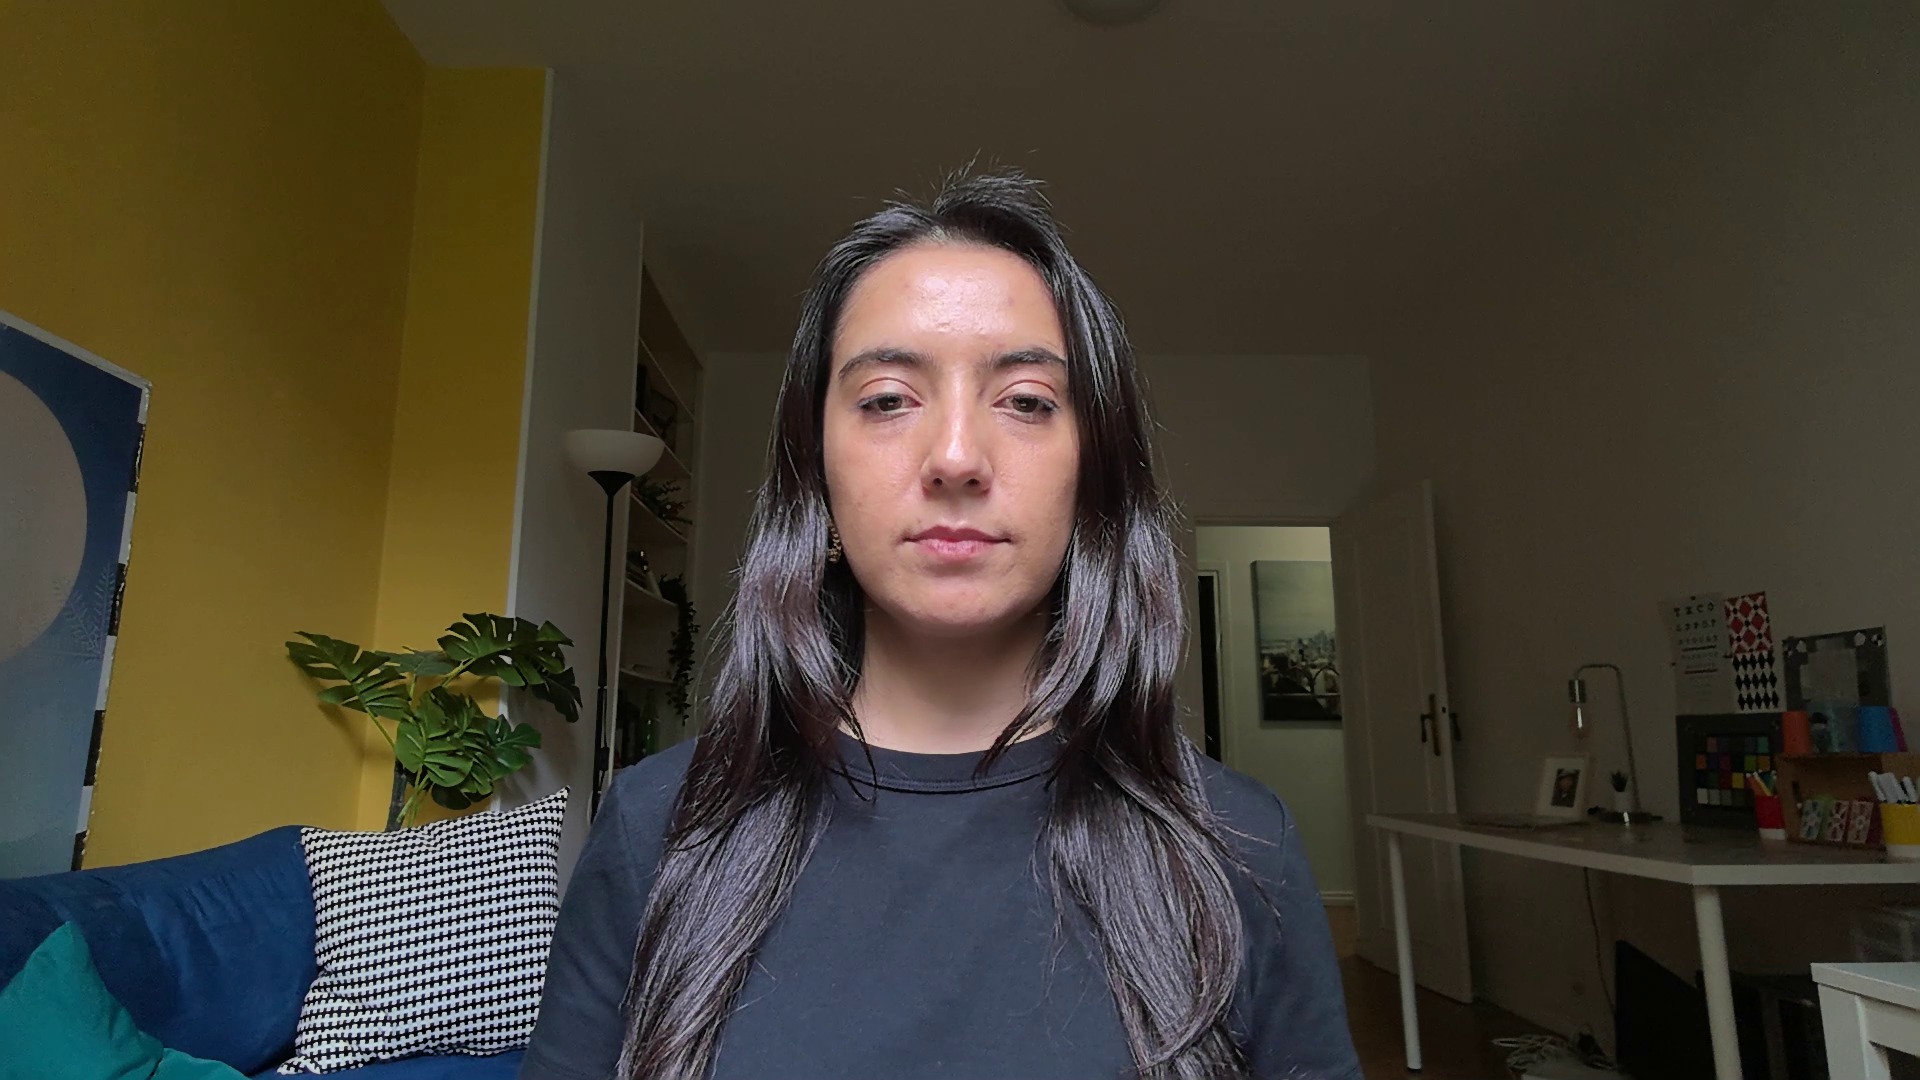
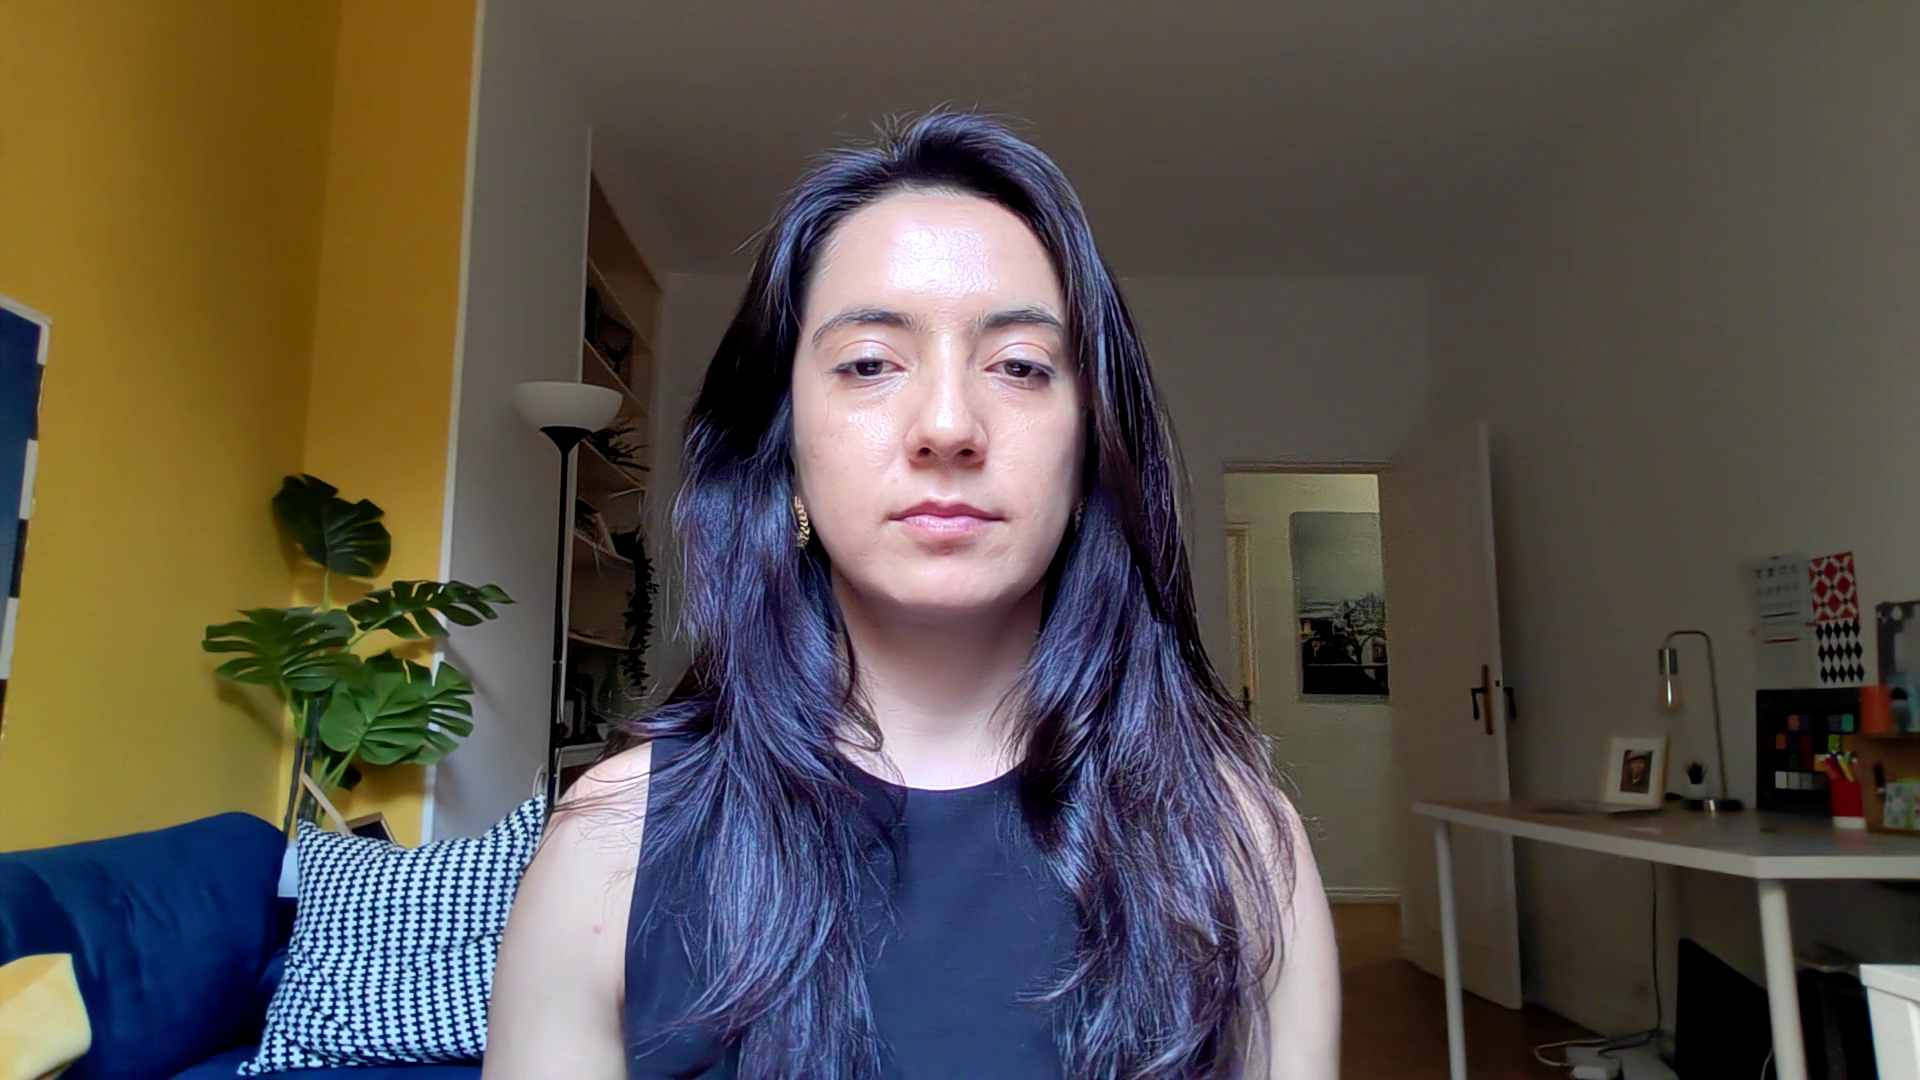
In our comprehensive evaluation of the Lenovo Yoga Slim 7x Gen9, the camera delivers a very high level of detail across the tested lighting conditions, making detail preservation one of the main strengths of its camera performance.
One of the key aspects delivered by the Lenovo Yoga Slim 7x Gen9 is its ability to maintain a high level of detail from bright environments to more challenging lighting conditions. Face exposure is also generally good, including in challenging lighting conditions, allowing faces to remain reasonably visible even when the scene contains more complex illumination. In bright conditions, color rendering is also acceptable during static video conferencing use cases, contributing to a generally pleasant image.
However, noise is very visible in indoor and low-light conditions, becoming particularly noticeable as the available light decreases. Some exposure and white balance instabilities can also be observed, particularly in challenging motion scenarios, affecting the consistency of the image. In all HDR scenes, noticeable clipping can occur, resulting in a loss of information in bright areas. Skin tone rendering is another area where the camera shows limitations, with inaccurate skin tones sometimes affecting the naturalness of the overall image.
Overall, the Lenovo Yoga Slim 7x Gen9 provides an impressive level of detail and good face exposure across a wide range of conditions. However, visible noise, HDR clipping, exposure and white balance instabilities and inaccurate skin tone rendering limit the overall consistency of the camera performance.
Lenovo ThinkPad X9 14” Aura Edition
Microsoft Surface Laptop 13.8” (8th Gen)
Test summary
About DXOMARK Laptop tests: For scoring and analysis in our laptop reviews, DXOMARK engineers perform a variety of objective tests and undertake more than 20 hours of perceptual evaluations under controlled lab conditions and real-life scenarios. (For more details about the Laptop protocol, click here.)
The following section gathers key elements of our exhaustive tests and analyses performed in DXOMARK laboratories. Detailed performance evaluations under the form of reports are available upon request. Do not hesitate to contact us.
Camera
88
Lenovo Yoga Slim 7x Gen 9
146
Microsoft Surface Laptop 13.8-inch
Microsoft Surface Laptop 13.8-inch
About DXOMARK Camera Laptop tests
DXOMARK evaluates the image quality of the built in camera during video calls, whether with a single person or with multiple people, in a variety of lighting conditions. Our camera evaluation particularly assesses the ability of the built-in camera to clearly render human faces during video calls. Other intrinsic camera quality aspects are also evaluated, like color reproduction, texture and noise, as well as artefacts.
Camera texture acutance on Deadleaves with illuminance levels (Eugene)
This graph shows the evolution of texture acutance with the level of lux measured on a Deadleaves chart.
Camera texture acutance on Deadleaves with illuminance levels (Eugene)
This graph shows the evolution of texture acutance with the level of lux measured on a Deadleaves chart.
Camera texture acutance on Deadleaves with illuminance levels (Eugene)
This graph shows the evolution of texture acutance with the level of lux measured on a Deadleaves chart.
Camera texture acutance on Deadleaves with illuminance levels (Eugene)
This graph shows the evolution of texture acutance with the level of lux measured on a Deadleaves chart.
Camera texture acutance on Deadleaves with illuminance levels (Diana)
This graph shows the evolution of texture acutance with the level of lux measured on a Deadleaves chart.
Camera texture acutance on Deadleaves with illuminance levels (Diana)
This graph shows the evolution of texture acutance with the level of lux measured on a Deadleaves chart.
Camera texture acutance on Deadleaves with illuminance levels (Diana)
This graph shows the evolution of texture acutance with the level of lux measured on a Deadleaves chart.
Camera texture acutance on Deadleaves with illuminance levels (Diana)
This graph shows the evolution of texture acutance with the level of lux measured on a Deadleaves chart.
Camera visual noise evolution with illuminance levels (Eugene)
This graph shows the evolution of spatial visual noise with the level of lux. Spatial visual noise is measured on the visual noise chart in the video noise setup. DXOMARK visual noise measurement is derived from ISO15739 standard.
Camera visual noise evolution with illuminance levels (Eugene)
This graph shows the evolution of spatial visual noise with the level of lux. Spatial visual noise is measured on the visual noise chart in the video noise setup. DXOMARK visual noise measurement is derived from ISO15739 standard.
Camera visual noise evolution with illuminance levels (Eugene)
This graph shows the evolution of spatial visual noise with the level of lux. Spatial visual noise is measured on the visual noise chart in the video noise setup. DXOMARK visual noise measurement is derived from ISO15739 standard.
Camera visual noise evolution with illuminance levels (Eugene)
This graph shows the evolution of spatial visual noise with the level of lux. Spatial visual noise is measured on the visual noise chart in the video noise setup. DXOMARK visual noise measurement is derived from ISO15739 standard.
Camera visual noise evolution with illuminance levels (Diana)
This graph shows the evolution of spatial visual noise with the level of lux. Spatial visual noise is measured on the visual noise chart in the video noise setup. DXOMARK visual noise measurement is derived from ISO15739 standard.
Camera visual noise evolution with illuminance levels (Diana)
This graph shows the evolution of spatial visual noise with the level of lux. Spatial visual noise is measured on the visual noise chart in the video noise setup. DXOMARK visual noise measurement is derived from ISO15739 standard.
Camera visual noise evolution with illuminance levels (Diana)
This graph shows the evolution of spatial visual noise with the level of lux. Spatial visual noise is measured on the visual noise chart in the video noise setup. DXOMARK visual noise measurement is derived from ISO15739 standard.
Camera visual noise evolution with illuminance levels (Diana)
This graph shows the evolution of spatial visual noise with the level of lux. Spatial visual noise is measured on the visual noise chart in the video noise setup. DXOMARK visual noise measurement is derived from ISO15739 standard.
Target exposure on face with illuminance levels in HDR conditions (Eugene)
These measurements take place on a setup combining realistic mannequins and a backlit panel simulating high dynamic range conditions. This graph shows the evolution of lightness measured on the forehead of the realistic mannequin with the level of lux, for multiple lighting conditions. The lightness is measured in L*. Delta EV specifies the difference of luminance in stops between the face and the light panel simulating HDR conditions.
Target exposure on face with illuminance levels in HDR conditions (Diana)
These measurements take place on a setup combining realistic mannequins and a backlit panel simulating high dynamic range conditions. This graph shows the evolution of lightness measured on the forehead of the realistic mannequin with the level of lux, for multiple lighting conditions. The lightness is measured in L*. Delta EV specifies the difference of luminance in stops between the face and the light panel simulating HDR conditions.

 English